01 / MBES motion
MBES motion compensate
Attitude and heave for port/channel multibeam.
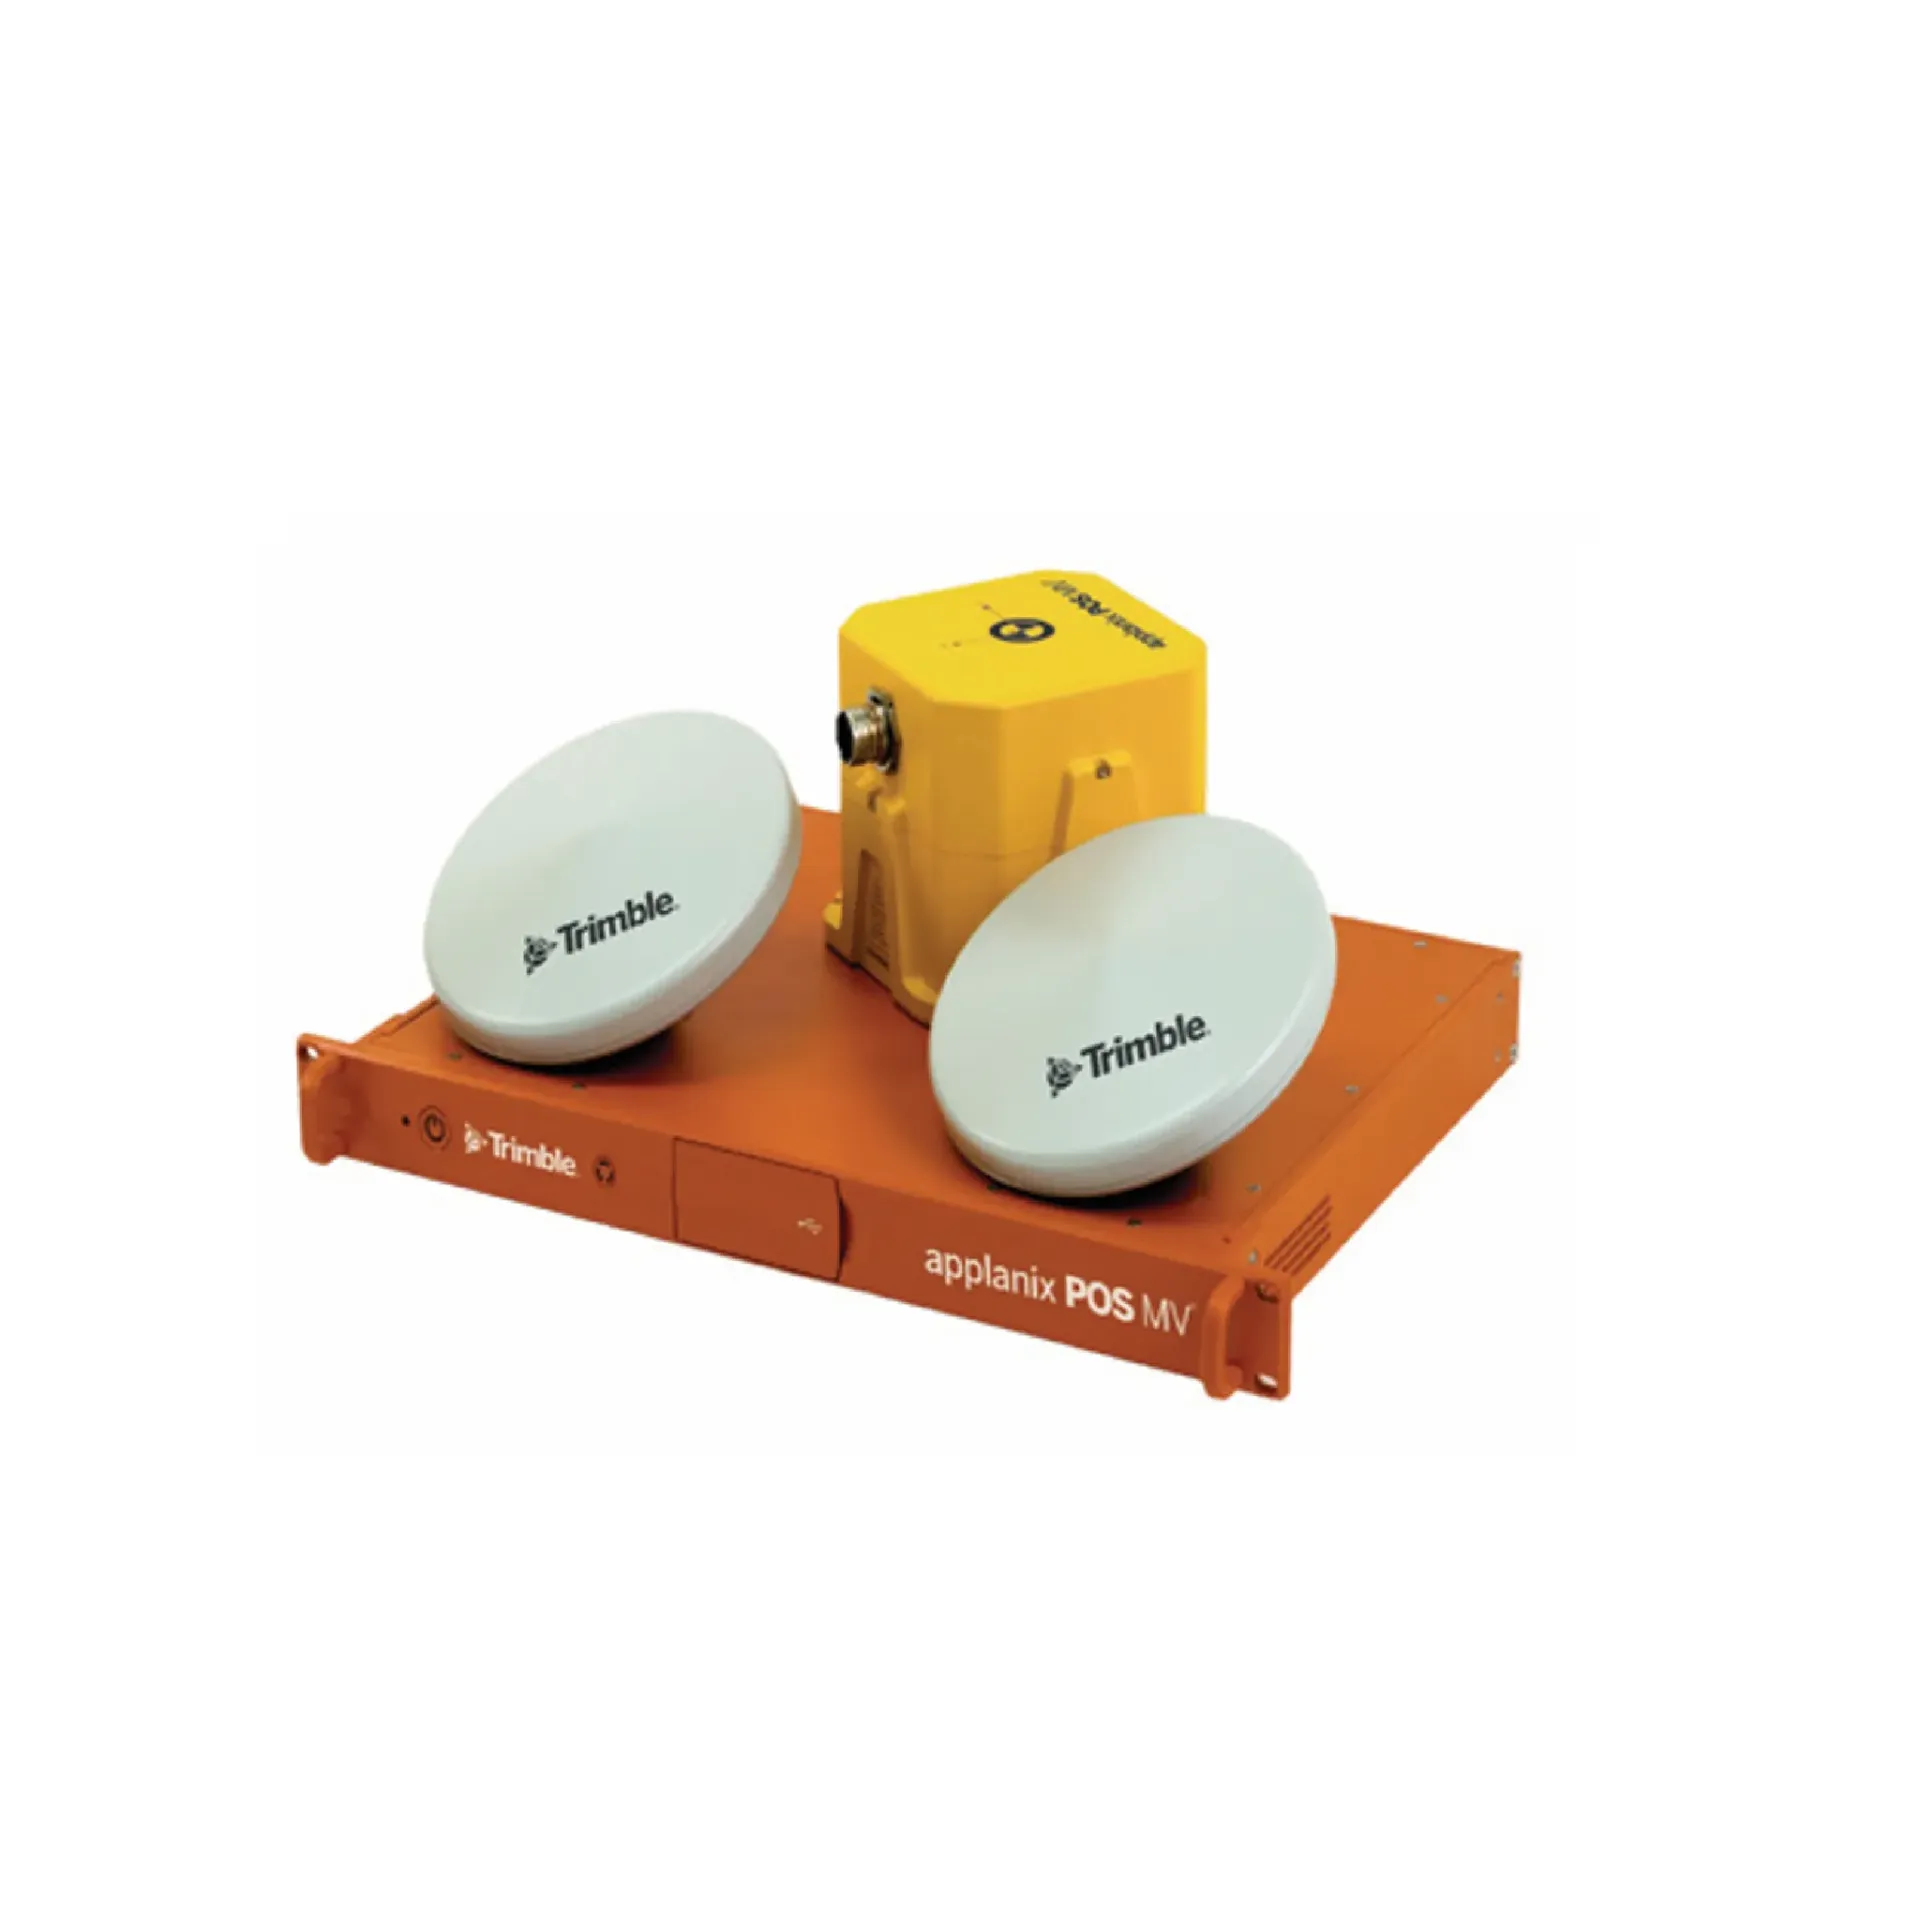
POS MV WaveMaster blends GNSS with IMU/GAMS for position,heading,attitude,heave and velocity;leaflet roll/pitch about 0.02°–0.03° class (config-dependent),TrueHeave about 2 cm or 2%. It focuses on GNSS + inertial fusion, TrueHeave, High-rate real-time, ready to connect with sounding, navigation, or monitoring workflows. Typical uses include MBES motion compensate, Hull heave monitor, Common sensor reference.
POS MV WaveMaster blends GNSS with IMU/GAMS for position,heading,attitude,heave and velocity;leaflet roll/pitch about 0.02°–0.03° class (config-dependent),TrueHeave about 2 cm or 2%.
Position,heading,attitude,heave and velocity in one output.
Leaflet TrueHeave ~2 cm or 2%,reducing long-period heave error.
Primary TCP/IP real-time out up to ~200 Hz (user selectable).
Rack PCS and multiple IMU install styles for varied hulls.
GNSS,IMU rates/accels and GAMS heading fuse into a 6-DoF solution;primary port up to ~200 Hz for multibeam motion correction.
Install GNSS antennas and IMU to baseline rules.
Real-time GNSS+IMU+GAMS fusion.
Attitude/heave out to sonar/sounding chains.
Optional trajectory refinement in post.
Core capabilities of POSMV Wavemaster for selection and project discussions.
Typical operating scenes and platform choices for POSMV Wavemaster.
Attitude and heave for port/channel multibeam.
Log heave and attitude change underway.
Common motion reference for sidescan,SBP and peers.
Positioning/attitude backbone on unmanned survey boats.
Key parameters for POSMV Wavemaster (from the product page and sales description).
| Model | POSMV Wavemaster |
| Brand | 南方海洋 |
| Product type | GNSS&RTK |
| Roll/Pitch | Roll/Pitch |
| Heave | 5 cm or 5% (whichever greater) |
| TrueHeave | 2 cm or 2% (whichever greater) |
| Rate | to ~200 Hz (selectable) |
| Key points | Fuses GNSS and inertial sensors for position,velocity,attitude,and heave. POS MV WaveMaster blends GNSS with IMU/GAMS for position,heading,attitude,heave and velocity;leaflet roll/pitch about 0.02°–0.03° class (config-dependent),TrueHeave about 2 cm or 2%. Typical use: MBES motion compensate;Hull heave monitor;Common sensor reference;USV attitude core. |
| Applications | MBES motion compensate;Hull heave monitor;Common sensor reference;USV attitude core |